

How it fits
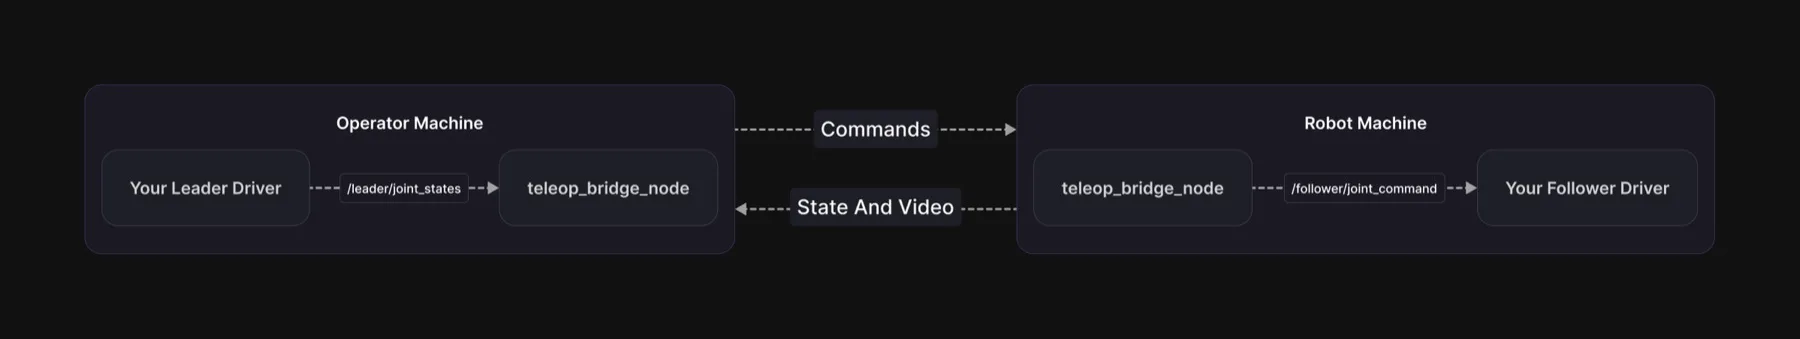
teleop_bridge_node is a bridge, never a driver. It owns no servo bus, no port
and no camera. It reads the topic your leader driver publishes, sends those
values to the other machine, and publishes them onto the topic your follower
driver subscribes to.
You run the same node on both machines, told which side it is on.
What the bridge handles
Everything between your two topics, and nothing on either side of them.
Rate limiting and position limits stay in your follower driver, which is closest
to the hardware and which you have already tuned. The bridge leaves
max_norm_step wide open for that reason.
Supported
ROS 1 is not supported.
Next
Quickstart
Install the bridge, point it at your topics, and drive a robot.
SO-101
Joint travel read from a LeRobot calibration instead of typed in.
Reference
Every parameter, topic and service the node takes.
Safety
The checks a command passes before it reaches the motors.