

Key terms
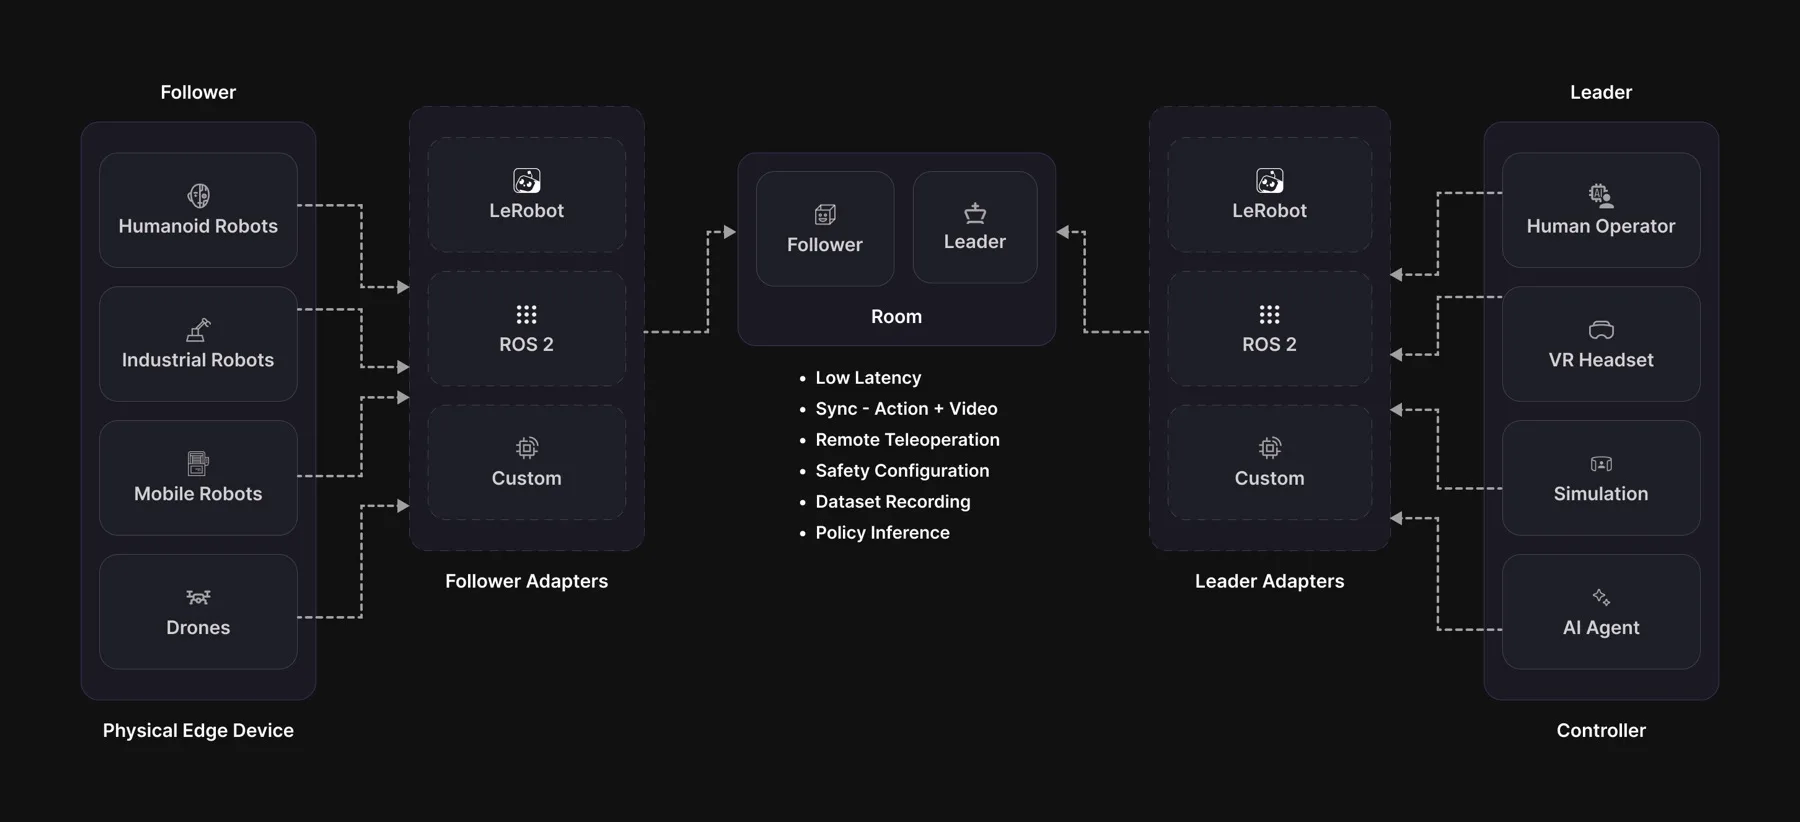
Room
The VideoSDK room both sides join, created through the VideoSDK API. Everything in a session travels through it, and a third participant can join to record without ever taking control.Session
One connected run: a follower and a leader in the same room. A room carries one session at a time, and it ends when either side closes its transport.Follower
The machine that moves: a robotic arm, a humanoid, a mobile base or a drone, real or simulated. It owns the cameras, the safety checks and the recording, and nothing moves until it grants control.Leader
The machine that decides how to move: a person on a backdrivable arm, a VR controller, a simulator or an AI model. It sends actions and never clamps them itself, because limits belong to the follower.Descriptor
The joint schema the follower announces: names, order, units and control rate. The leader compares it against its own when control is granted, and declines if they differ.Observation
A snapshot of the robot at one moment: where every joint is, and a picture from each camera. The follower keeps the two in sync for you and tags the pair with a number.Action
Where the leader wants the joints to go next. The follower checks every action against its limits before the motors see it, so the movement can end up smaller than what was asked for.Tick
A follower tick checks that actions are still arriving, applies the newest one through the limits, writes to the motors, and every few ticks sends an observation. A leader tick reads the operator’s pose and sends it, as long as it holds the lease and the deadman, and keeps a heartbeat going either way. Calltick() from your own scheduler, or let run(hz) pace it for you.
Lease
Permission to command the follower. One holder at a time, granted and revoked by the follower.Deadman
The hold-to-drive control on the leader. Actions flow only while it is held, and letting go stops them, which leaves the follower holding position.How they fit together
For example, you are driving an arm toward a cube on a table.- Ten times a second the follower takes a snapshot: where the joints are, and
what the camera sees. Every snapshot gets a number, say
302. - You see the cube on your screen and move your controller toward it. The
leader sends that position back along with
302, so the follower knows which snapshot you were reacting to. - The follower checks the position against its limits, moves the arm, and
records the snapshot and the movement together under
302.
Related
Safety
The checks a command passes before it reaches the motors.
Sync
How video and joint readings are matched to the same moment.
Follower
What one tick does, gate by gate.